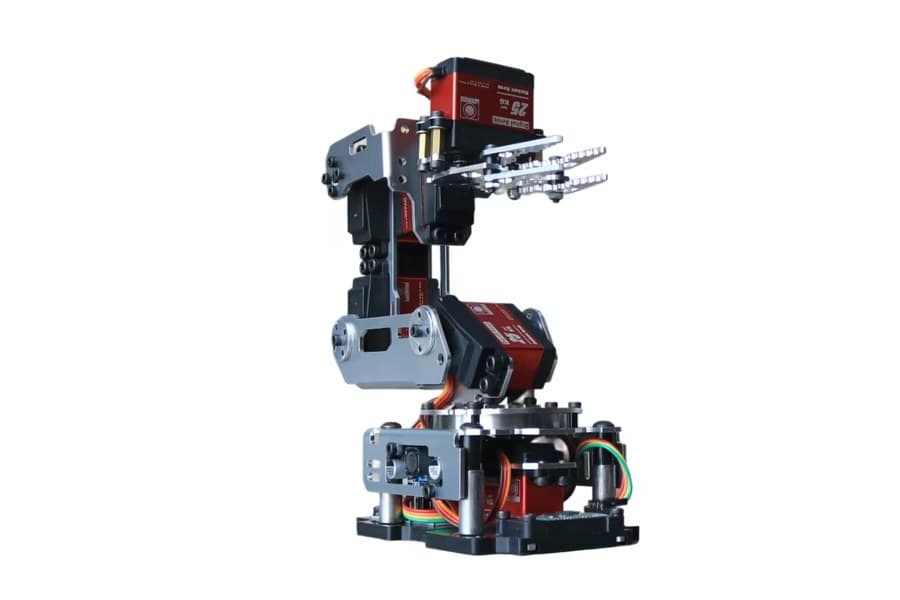
Robotic Arm
A desktop robotic arm built joint by joint. You will wire and calibrate each servo, learn how a multi-axis arm converts angles into position, and finish with an arm that can pick up, move and place objects under your own code.
What you’ll learn
- Multi-servo joint control and calibration
- Forward kinematics — turning angles into position
- Gripper control for picking and placing
- Programmable movement sequences
Class list
Work through these in order — finishing one unlocks the next. Complete them all and you earn 500 XP.
Class 1: What Is a Robotic Arm?
Ready to start
Class 2: Parts of a Robotic Arm
Pop the hood and meet every piece
Locked — finish the previous class
Class 3: Electronics Basics for Robotics
Locked — finish the previous class
Class 4: Servo Motors: The Muscles of Your Robot
Precision movement, one degree at a time
Locked — finish the previous class Code
Class 5: Programming Basics: Controlling Your Robot With Code
Give your robot instructions it can actually follow
Locked — finish the previous class Code
Class 6: Degrees of Freedom (DOF)
Locked — finish the previous class
Class 7: End Effector: The Gripper Control
Locked — finish the previous class Code
Class 8: Coordinates and Movement: The X, Y, Z System
How robots know exactly where to go
Locked — finish the previous class
Class 9: Automation: How Robots Work by Themselves
Push one button, watch the magic happen
Locked — finish the previous class Code
Class 10: Motion Sequences: How Robots Move Step by Step
Locked — finish the previous class Code
Class 11: Robot Assembly: Building Your Robotic Arm
Locked — finish the previous class Code
Class 12: Final Remarks: Your First Step Into Robotics
Locked — finish the previous class